I will be a joint PhD student at Shanghai Qi Zhi Institute (SQZ) starting in Fall 2027, conducting research under the supervision of Alex Lamb in his group at Tsinghua University.
My research focuses on multimodal perception and fusion for quadruped and humanoid robots. I study vision-olfaction fusion for robot navigation and whole-body tactile learning for humanoid loco-manipulation.
I am an undergraduate in Digital Media Art at the Communication University of China (2023–2027), with a curriculum focused on human-computer interaction. My research experience spans Tsinghua University’s Future Laboratory, TEA Lab with Huazhe Xu, and Xu Lab with Mengdi Xu.
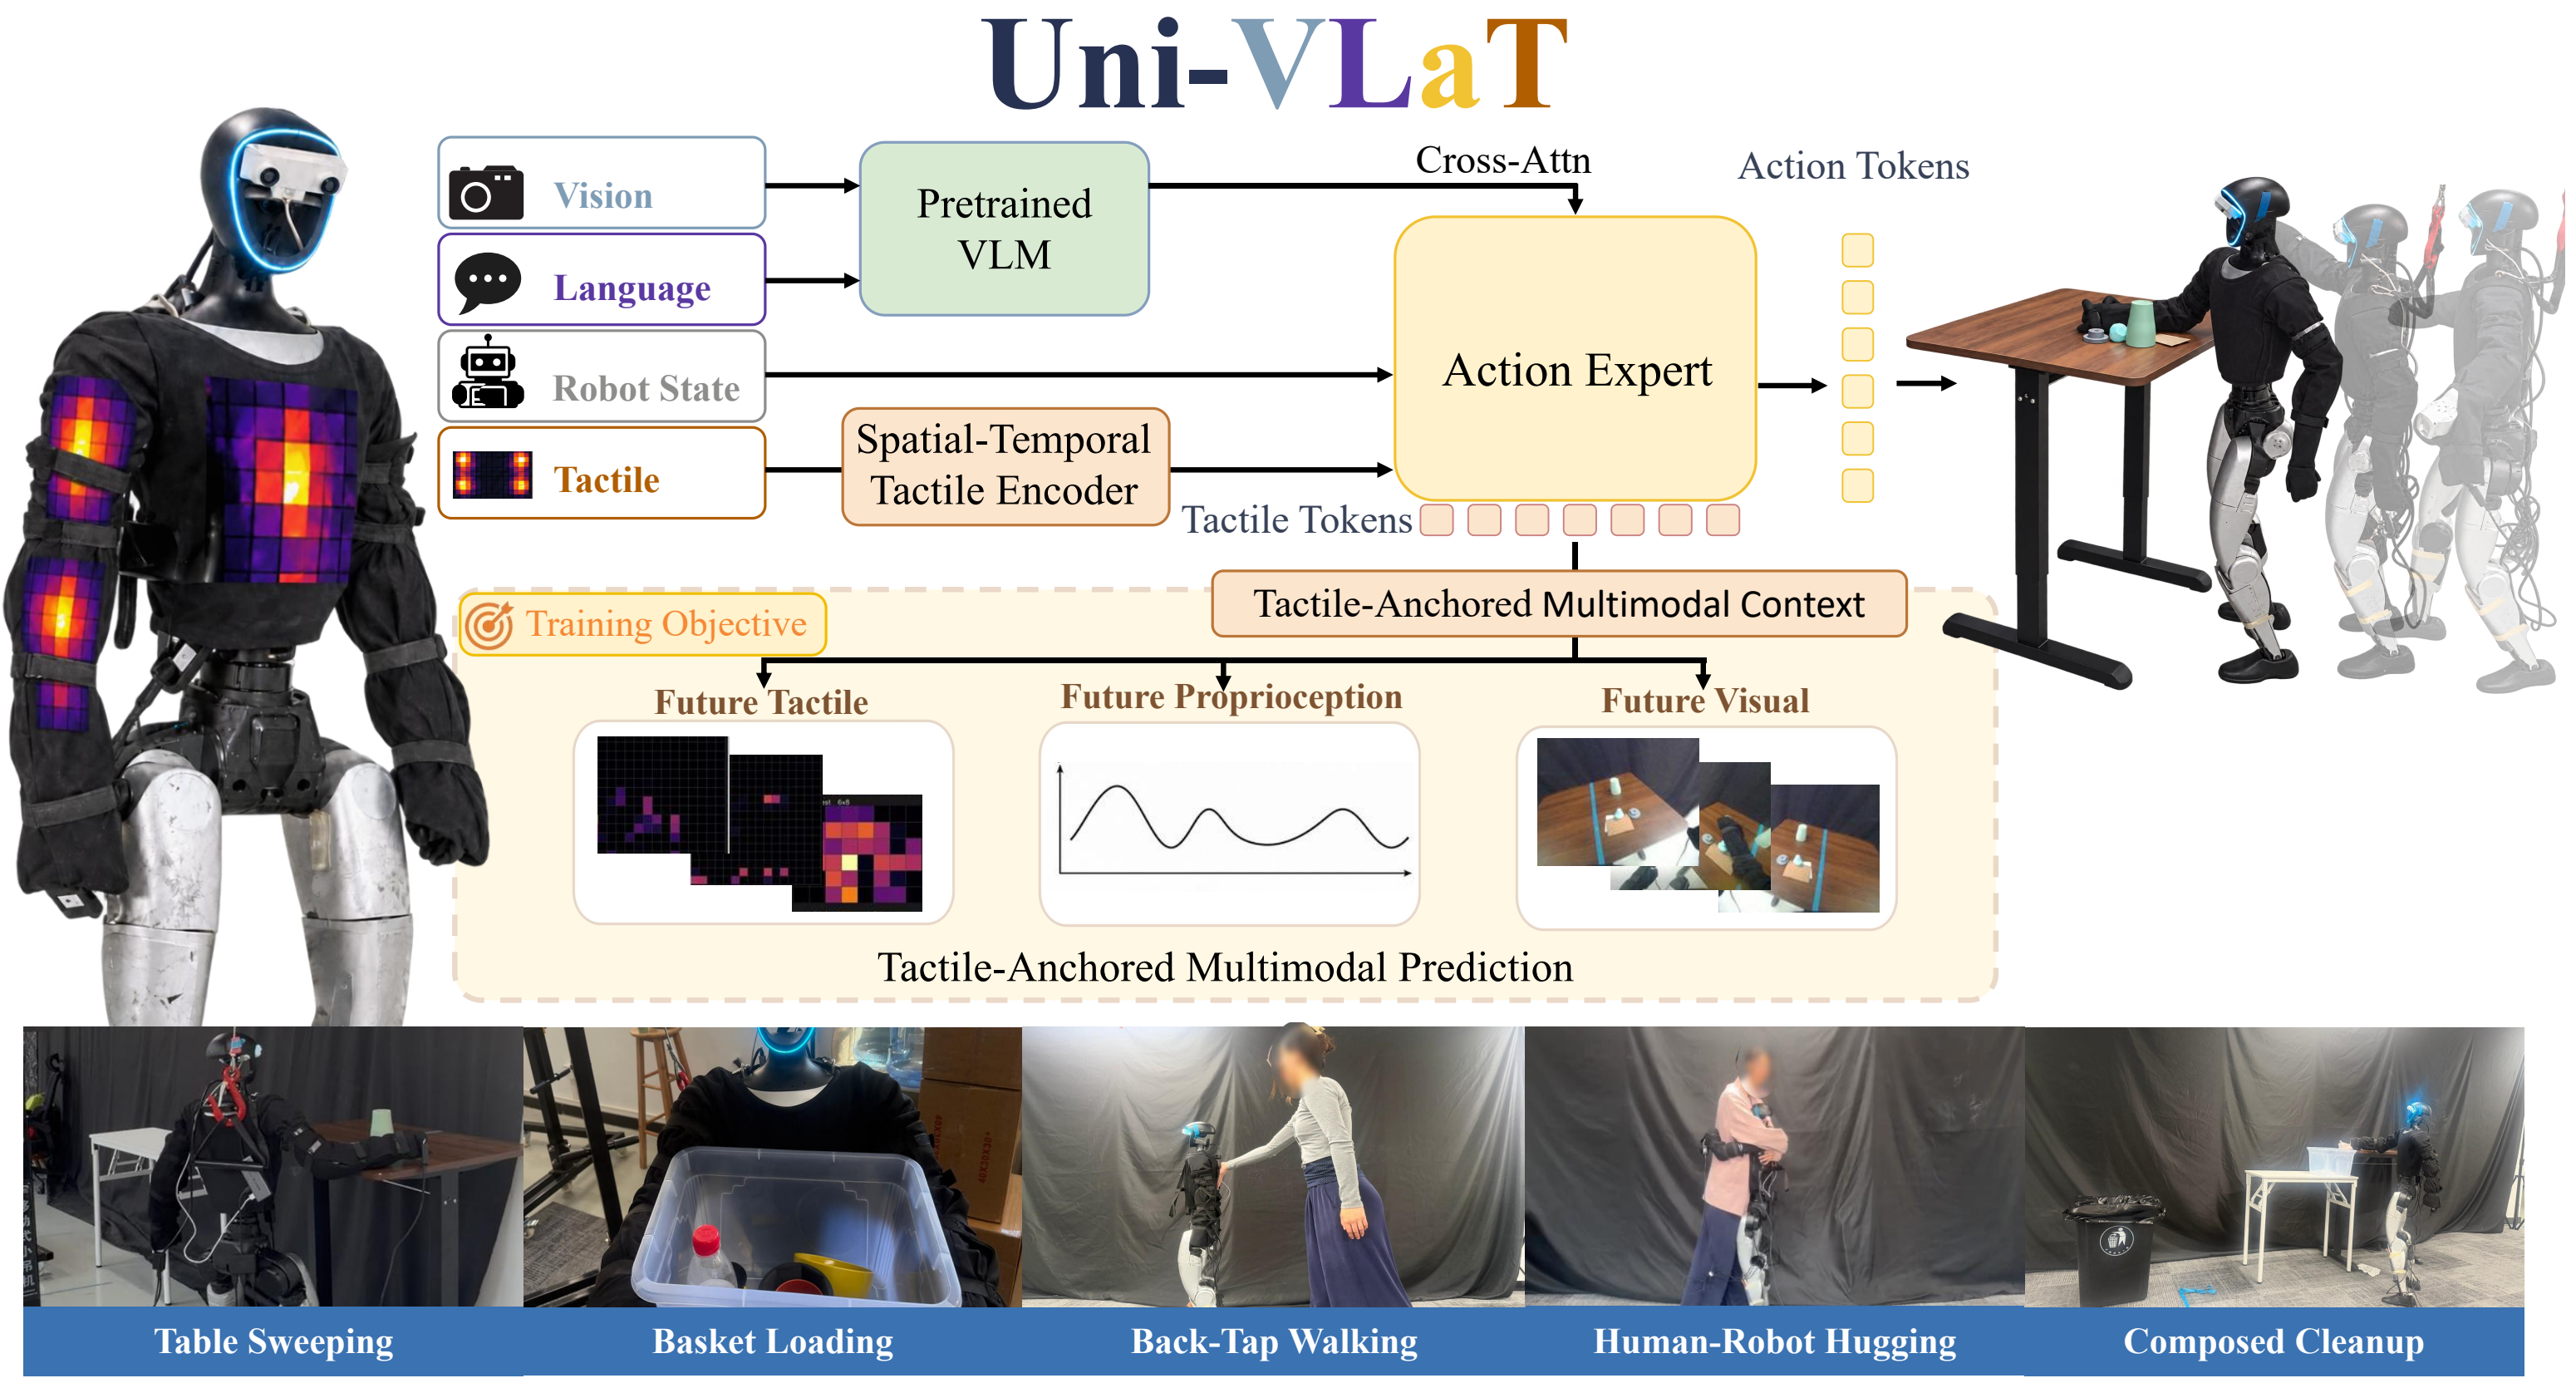
Adapting pretrained vision-language-action policies with whole-body touch and tactile-anchored multimodal prediction for contact-rich humanoid control.
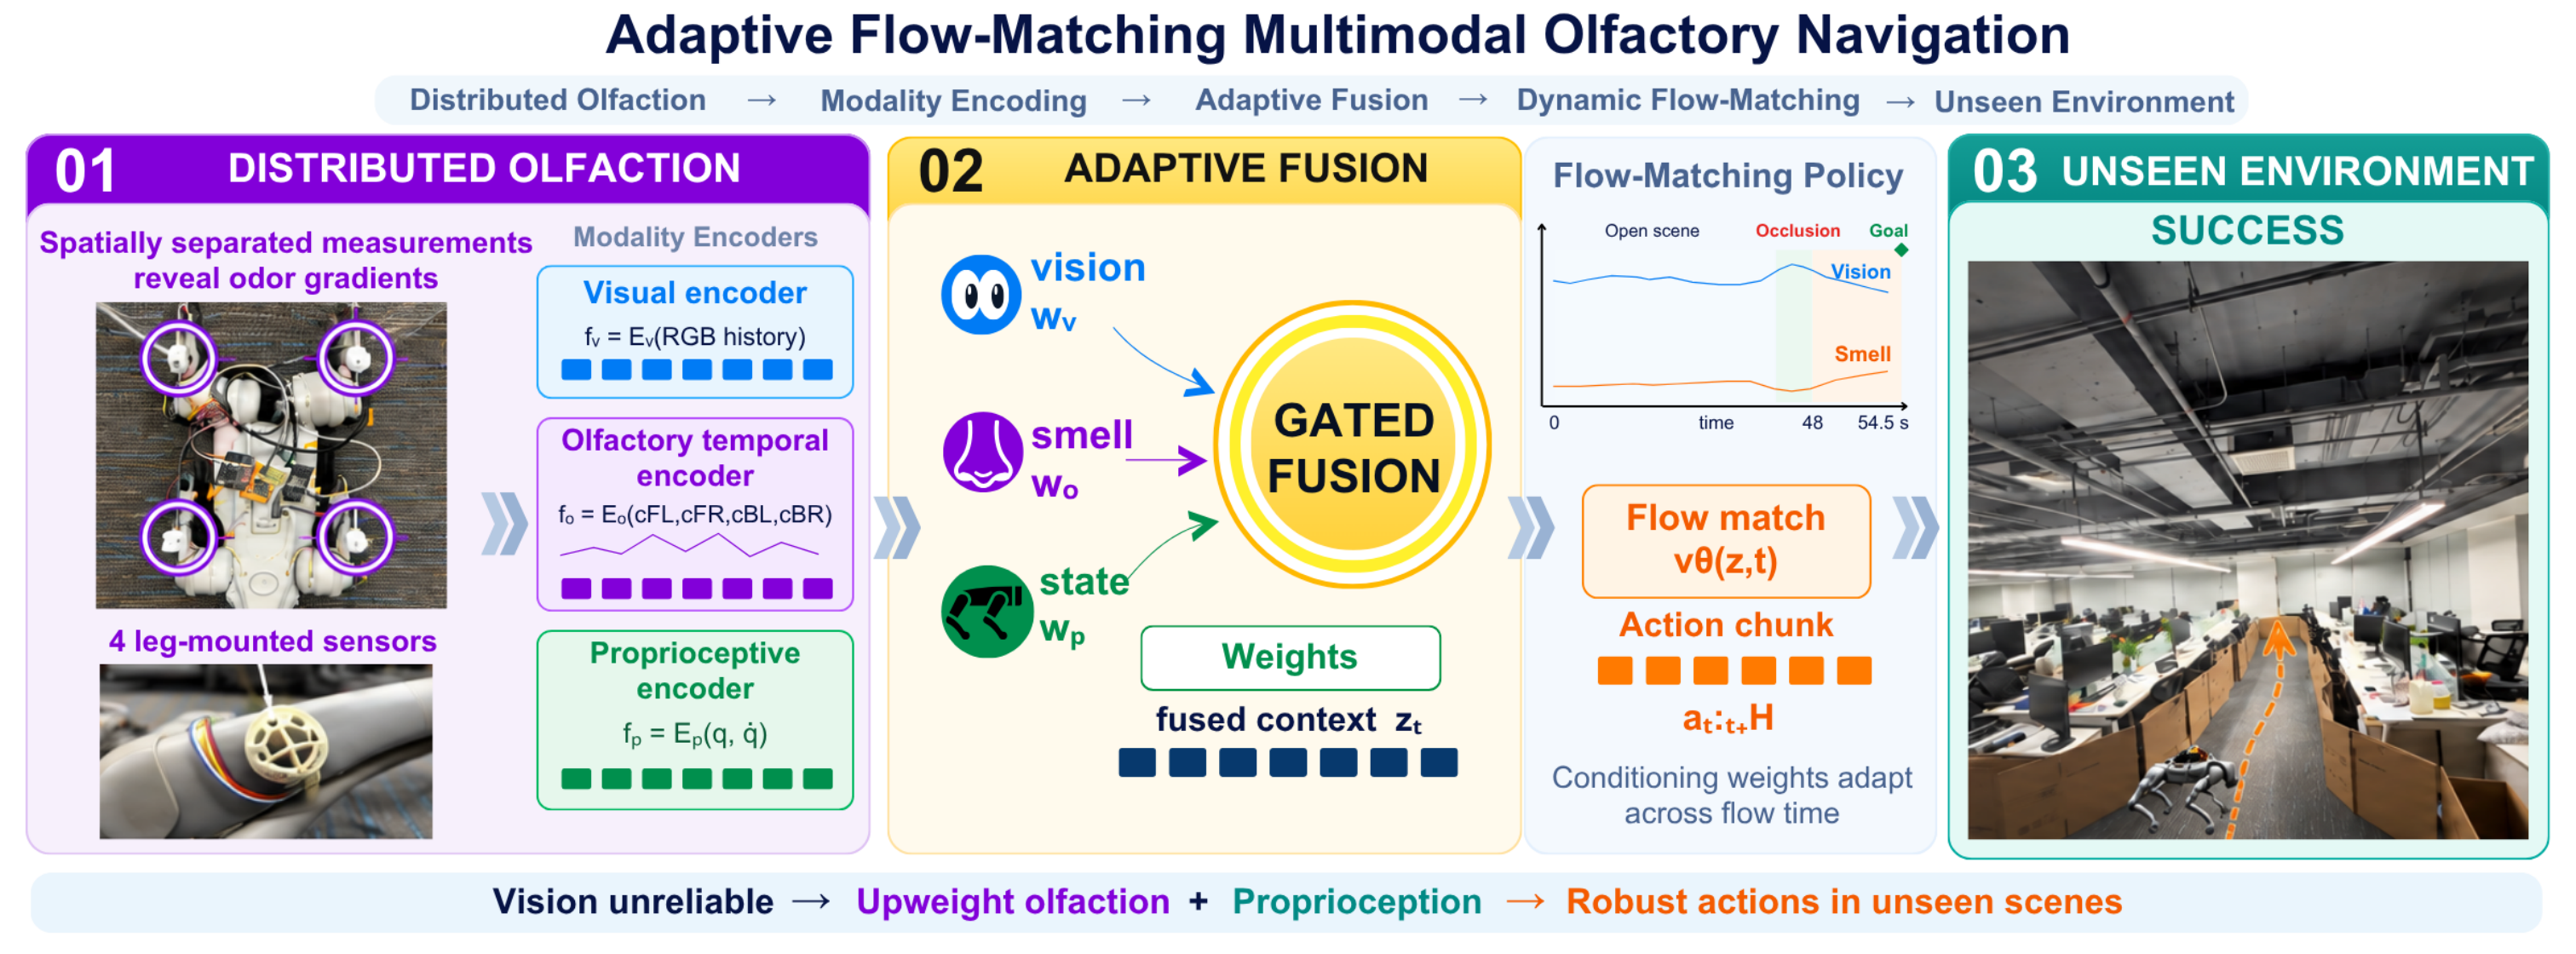
VismellNav: Learning Vision-Olfaction Fusion for Robust Odor Source Navigation
Fusing vision, distributed olfactory sensing, and proprioception with an adaptive flow-matching policy to guide quadrupeds toward hidden odor sources in unseen environments.
03
CHI 2026Olfactory HCI
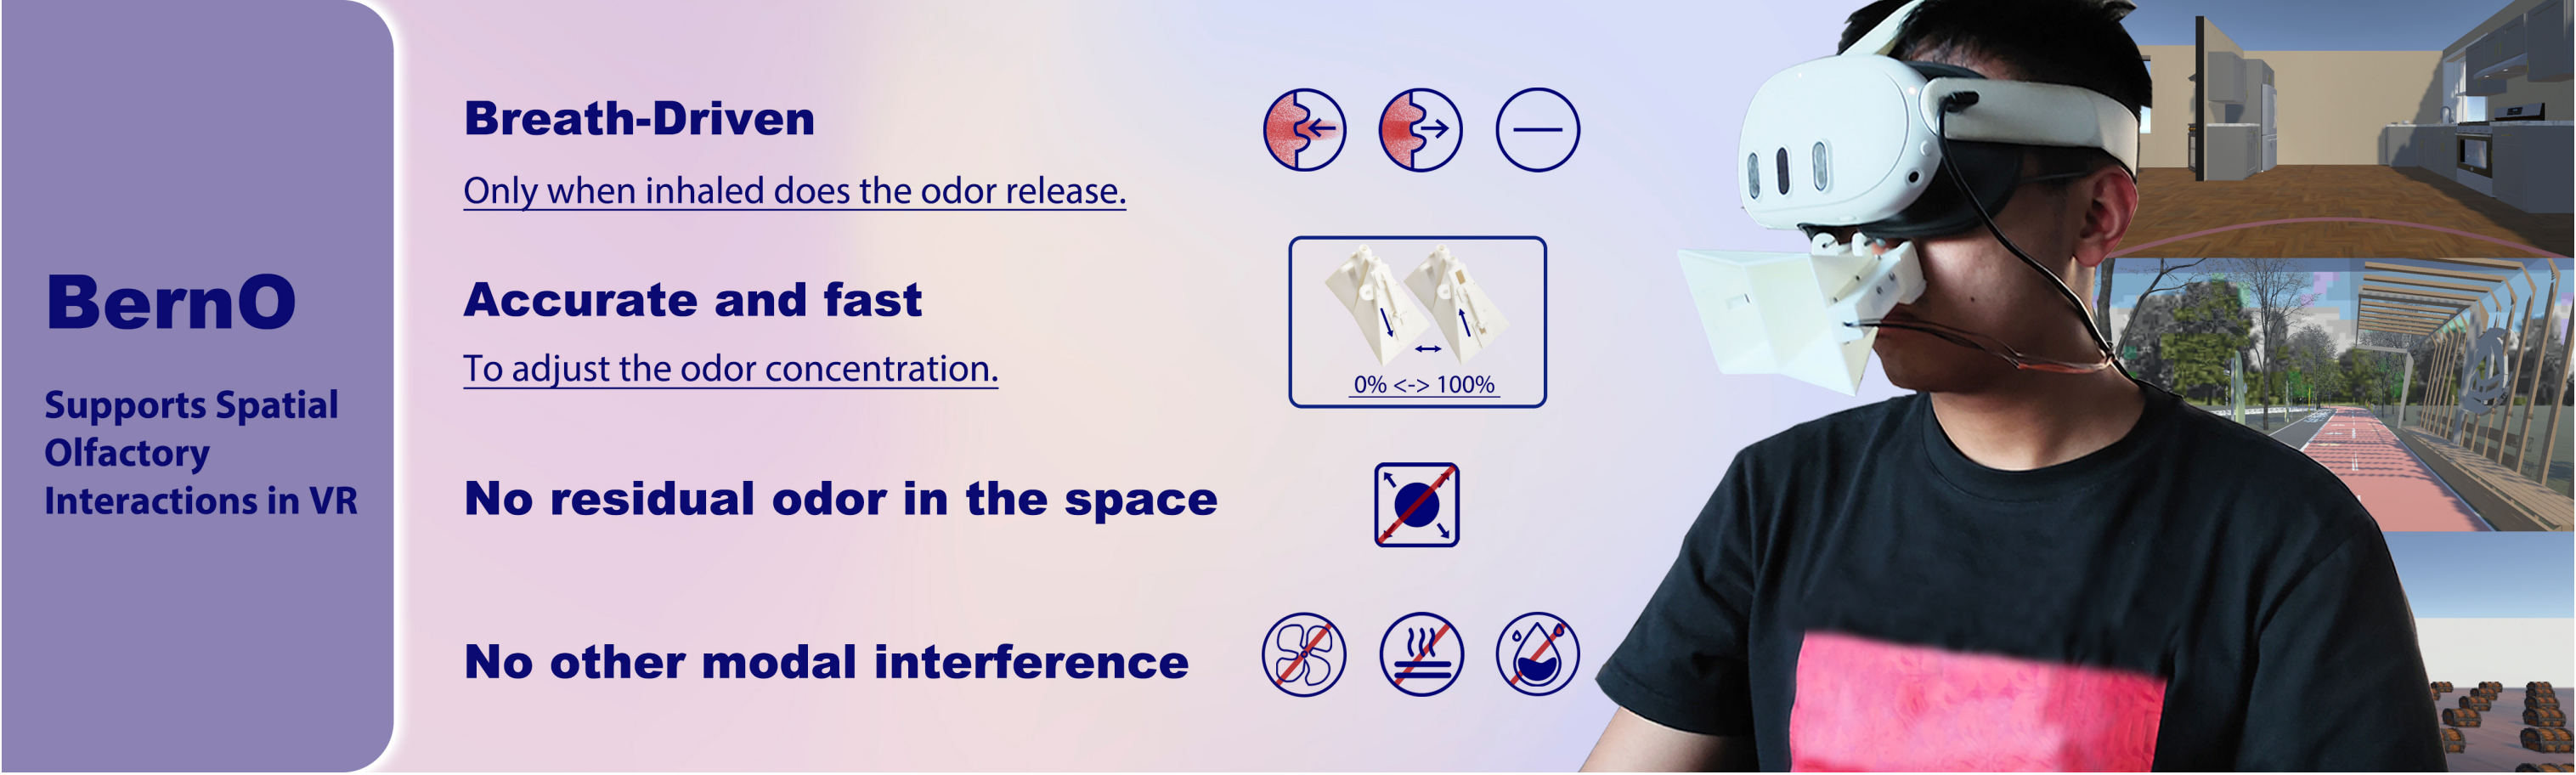
BernO: A Breath-Driven Odor Display for Spatial Olfactory Interaction in VR